
Control Theory After Eight Years: The Toolbox Nobody Wants Until Something Breaks
Embodied AI keeps getting the headlines. Control theory keeps getting the job of telling everyone when the system is about to fail.
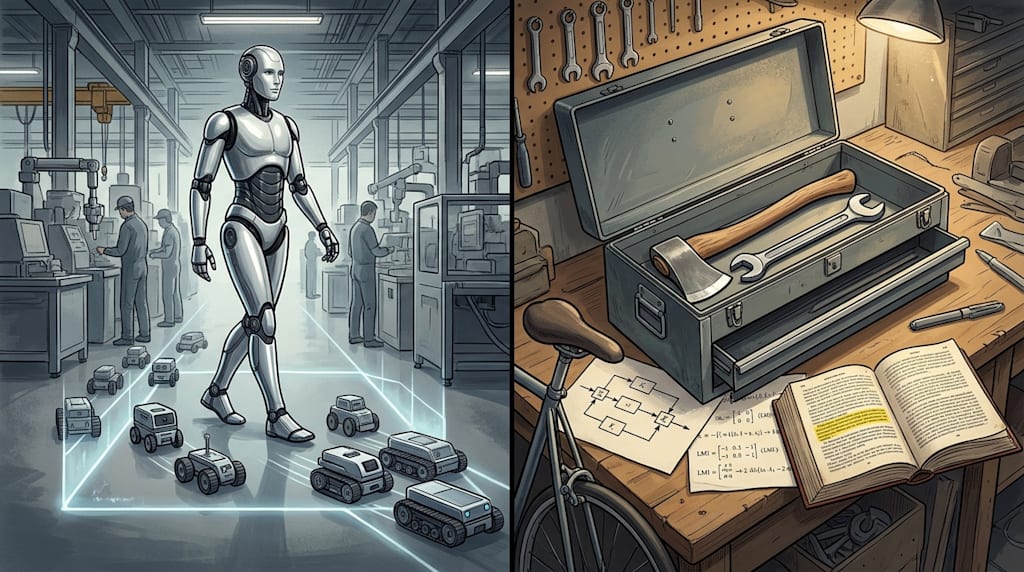
This series is eight years old. I skipped 2019. In 2020 I wrote about the gap between models and deployed systems, and what that gap does to control performance. In 2021 I wrote about what makes a system distinctive, how to describe that distinction, what you want to achieve, and how to achieve it. In 2022 I wrote about the difference between a new result and a good result. In 2023 I wrote about how to get new ideas. The 2024 answer was longer, and it asked where embodied AI and control theory should each develop. The 2025 answer continued that line. Looking back, those six posts trace a shift. They move from the usual control-theory research questions to a slightly defensive attempt to explain that control theory is not useless. That is the polite version. The less polite version is that the field has spent some time asking whether it still has a reason to exist.
This year looks familiar. Embodied AI is still booming. Control is still lukewarm. If you say control is useless, look at the number of embodied systems that have failed in the field. Even the most aggressive technology executive will not throw away every fallback. If you say control is useful, that is obvious too. In industry and in academia, pure control-theory groups and jobs are getting fewer. The consensus among a large group of people is simple: useful, yes; worth hiring many people to research, no. The fruit in this field is mostly gone.
There are still unsolved problems in control. Plenty of them. The field is not exhausted. But those problems tend to have one of three properties. They have engineering substitutes. They are too hard and people avoid them. Or solving them would not improve much. That is why many journals now push experiments. Part of the reason is obvious: experiments verify claims. But control theory already has mathematics doing most of that work. The sharper reading is less comfortable. If theory is not producing big breakthroughs, journals want to see whether the combined system shows a clear metric.
A reader might conclude that this field is no longer worth research effort, only study. Just let control serve as the fallback for embodied AI. But fallback is a strange word. Think of a beginner on a bicycle. Someone tells you to lower the seat so that if something goes wrong, you can put your feet down and stay upright. After a few months, you almost never use your feet to brake. Fallback works the same way. As technology improves, it gets triggered less often.
Some students will say that this field is still good for publishing. That used to be true. Everyone in the field has heard of the mix-and-match paper. Combine method A with system B, add a simulation, and publish. This year, people report that mix-and-match work is both boring and harder to place. Rejection rates are rising. People joke that acceptance now requires luck. With that path narrower and no new shortcut in sight, the remaining option is to attack open problems. If you solve one, you get glory. If you fail, nobody questions your ability.
At that point the story sounds finished. It sounds as if control theory has exhausted its possible breakthroughs. It sounds as if no amount of understanding system features, problem structure, or obscure branches will save you from a head-on fight.
This year gave me a different view. The view is simple: pretend you are an outsider who knows nothing, and pretend you are an expert in the application domain.
Outsider view one: from “if it can be solved, it can be used” to “can it actually be solved?”
We design a system. We propose an algorithm. We prove that if the algorithm can find a set of gains, the scheme works. We then give a simulation example where the gains are found. This is a standard control paper. We have used this pattern to solve many problems, and we have gotten used to it.
An outsider asks a basic question. Is it guaranteed to be solvable? The paper says that if you solve it, it works. How do I know my system can solve it?
That question opens work. We can look for a necessary and sufficient condition. A necessary and sufficient condition guarantees solvability. The trouble is that it often sits in old classical results. Insiders often know that for most systems the algorithm can be solved. We do not even need to care whether it can be solved, because one example is enough to persuade us. Slowly, the guarantee gets forgotten. It becomes common sense. Then people use it when it does not hold. Someone asks how that is possible. It happens often enough that even TAC papers crash on this point.
I am not denying the value of existence proofs. An existence proof says the path is theoretically open. Engineering use asks a different question. For this class of systems, when is the path guaranteed to work? When is it guaranteed to fail? If it fails, is the problem the model, the constraints, the communication, or the algorithm? Mathematically, these questions become solvability conditions, feasibility conditions, conservativeness, and the gap between necessary and sufficient conditions. They are not new. They are as old as the wrench at the bottom of the toolbox. But the more they are treated as common sense, the easier they are to miss in deployed systems.
Outsider view two: the domain expert does not know control, but knows what counts as good enough
In earlier posts I wrote about looking for obscure problems. Even consensus has variants: bipartite consensus, group consensus, cluster consensus, interval consensus. Stability has practical stability. In recent years, some of those obscure branches have become crowded. In other cases, the limits of a method became clear, so people moved to control objectives that used to be obscure. That is why recent papers often say “method X can only achieve problem Y.” Once the obscure becomes popular, you have to look for the obscure within the obscure. Branches that almost nobody knows are hard to find.
So I tried another kind of outsider. This outsider is an expert in the application domain. They do not know control. They know the scenario. Their goal is to get control into that scenario.
Consider an error that fluctuates inside a range but never goes to zero. A control theorist may see this as a violation of stability. A domain expert says: that is fine. I do not need it to stay at zero. I need it not to leave my range. Another scenario: I need these three variables stable. The rest can run. If “run” sounds too loose, then I need those variables not to run away. In swarm control, we often want to drive a large group to a precise target. Sometimes it is enough to drive them past a line, like herding sheep. Sometimes it is enough that the main force gets there, and losses are acceptable. Then control energy matters. You do what you can.
If you raise these problems without the scenario, people find them strange. They ask whether the problem is real, useful, or meaningful. If you are the domain expert, or you talk to one, the problem is concrete. You abstract it, you solve it, and you explain it clearly. People stop objecting.
There is a risk here. A domain expert can raise a real need, but not every real need becomes a good paper. Bounded error, partial-state constraints, herding-style driving, acceptable losses, and limited energy are good starting points. They still need to become definable, reproducible, comparable, and transferable claims. Otherwise the work slides from mix-and-match into case engineering. Control theory can contribute something more useful than saying “this scenario matters.” It can translate “good enough” into a statement about conditions, metrics, system class, and guaranteed degree.
Methods are not owned by disciplines
One more observation may annoy some friends. I will record it anyway.
When I study application scenarios, I often feel that control can work well, but another method works better right now. The question shifts from “what is my discipline?” to “what method actually works for this problem?”
For years I did not understand why we give controlled objects autonomy. Why not model the object as a machine that follows a formula without deciding anything? When I reviewed papers on autonomy, I usually asked one question: what benefit does autonomy actually give you? You cannot introduce autonomy and then weaken it with your method so that the result is roughly the same as before. An outsider will not be convinced.
After more exposure, I understand the other side. Sometimes autonomy is necessary. Sometimes it is a reluctant compromise. In some scenarios, if you do not give the object autonomy, you have to make every decision for it. The decision logic becomes complicated, and you realize you cannot do it by hand.
That is the rough view I got this year from looking at control from the embodied side. Control does not need to prove to everyone that it is irreplaceable. It needs to be clear about where it provides system-level guarantees. As embodied AI moves into the field, learning, planning, perception, optimization, and control will not replace each other. They will expose each other’s boundaries. If control theory only guards its own toolbox, it will look slow. If it makes stability, constraint satisfaction, reliability, interpretable boundaries, and failure modes the base of embodied systems, then it is not a fallback. It is a foundation.
Closing: the axe and the wrench should stop fighting
In 2024 I was responding to embodied AI and trying to find the meaning of control. In 2025 I found that meaning and learned more about embodied AI. Those two years looked at embodied AI from the control side. This year looks at control from the embodied side. The puzzle is starting to fill in. Some discussions this year drifted away from control, and those are not part of this post.
This is not a lament for control theory. It is not cold water on embodied AI either. It is a positioning note. Control theory does not need to keep proving that it is useful. Usefulness has been verified in the field. It also does not need to treat fallback as an insult. The value of fallback is not only in how often it triggers. The value is in defining the boundary of failure. The more aggressive embodied AI becomes, the more valuable that boundary becomes. The more complex the scenario, the more valuable solvability conditions and a clear account of “good enough” become.
Disciplines are like an axe and a wrench. Stop fighting. Rest in the toolbox. The axe does not need to envy the wrench’s popularity. The wrench does not need to think the axe is obsolete. As embodied AI moves into the field, the toolbox cannot contain only the shiniest tool. The new work for control theory this year is not to prove again that it is useful. It is to ask questions with the domain expert’s mouth, find holes with the outsider’s eyes, and nail the answer down with an insider’s mathematics.
I do not know what next year will bring. But this year, looking back from the embodied side, I think the control toolbox still has to stay. Not because it is used every day, but because sometimes, without it, you cannot even say clearly when it cannot be used.
About the Creator
Jin
Writer of reamstories
https://reamstories.com/jin
Enjoyed the story? Support the Creator.
Subscribe for free to receive all their stories in your feed. You could also become a paid subscriber, letting them know you appreciate their work.
Comments
There are no comments for this story
Be the first to respond and start the conversation.